Carnegie Mellon
M.S. and B.S. in Electrical & Computer EngineeringAug 2010 - Dec 2014
Earned an M.S. in Electrical & Computer Engineering, GPA 4.00/4.00 · Dec 2014.
Earned a B.S. in Electrical & Computer Engineering with a minor in Business Administration · May 2014.
Made the Dean's List, Carnegie Institute of Technology · 2012, 2013, 2014.
NSF ResearchNSF Cyberphysical Systems ResearcherFeb 2013 - Aug 2013Carnegie Mellon University
Designed a bacterial simulator to replace live culture experiments.
LeanFMFull-Stack Web Developer InternDec 2013 - Feb 2014LeanFM Technologies
Developed a Django admin interface for building managers.
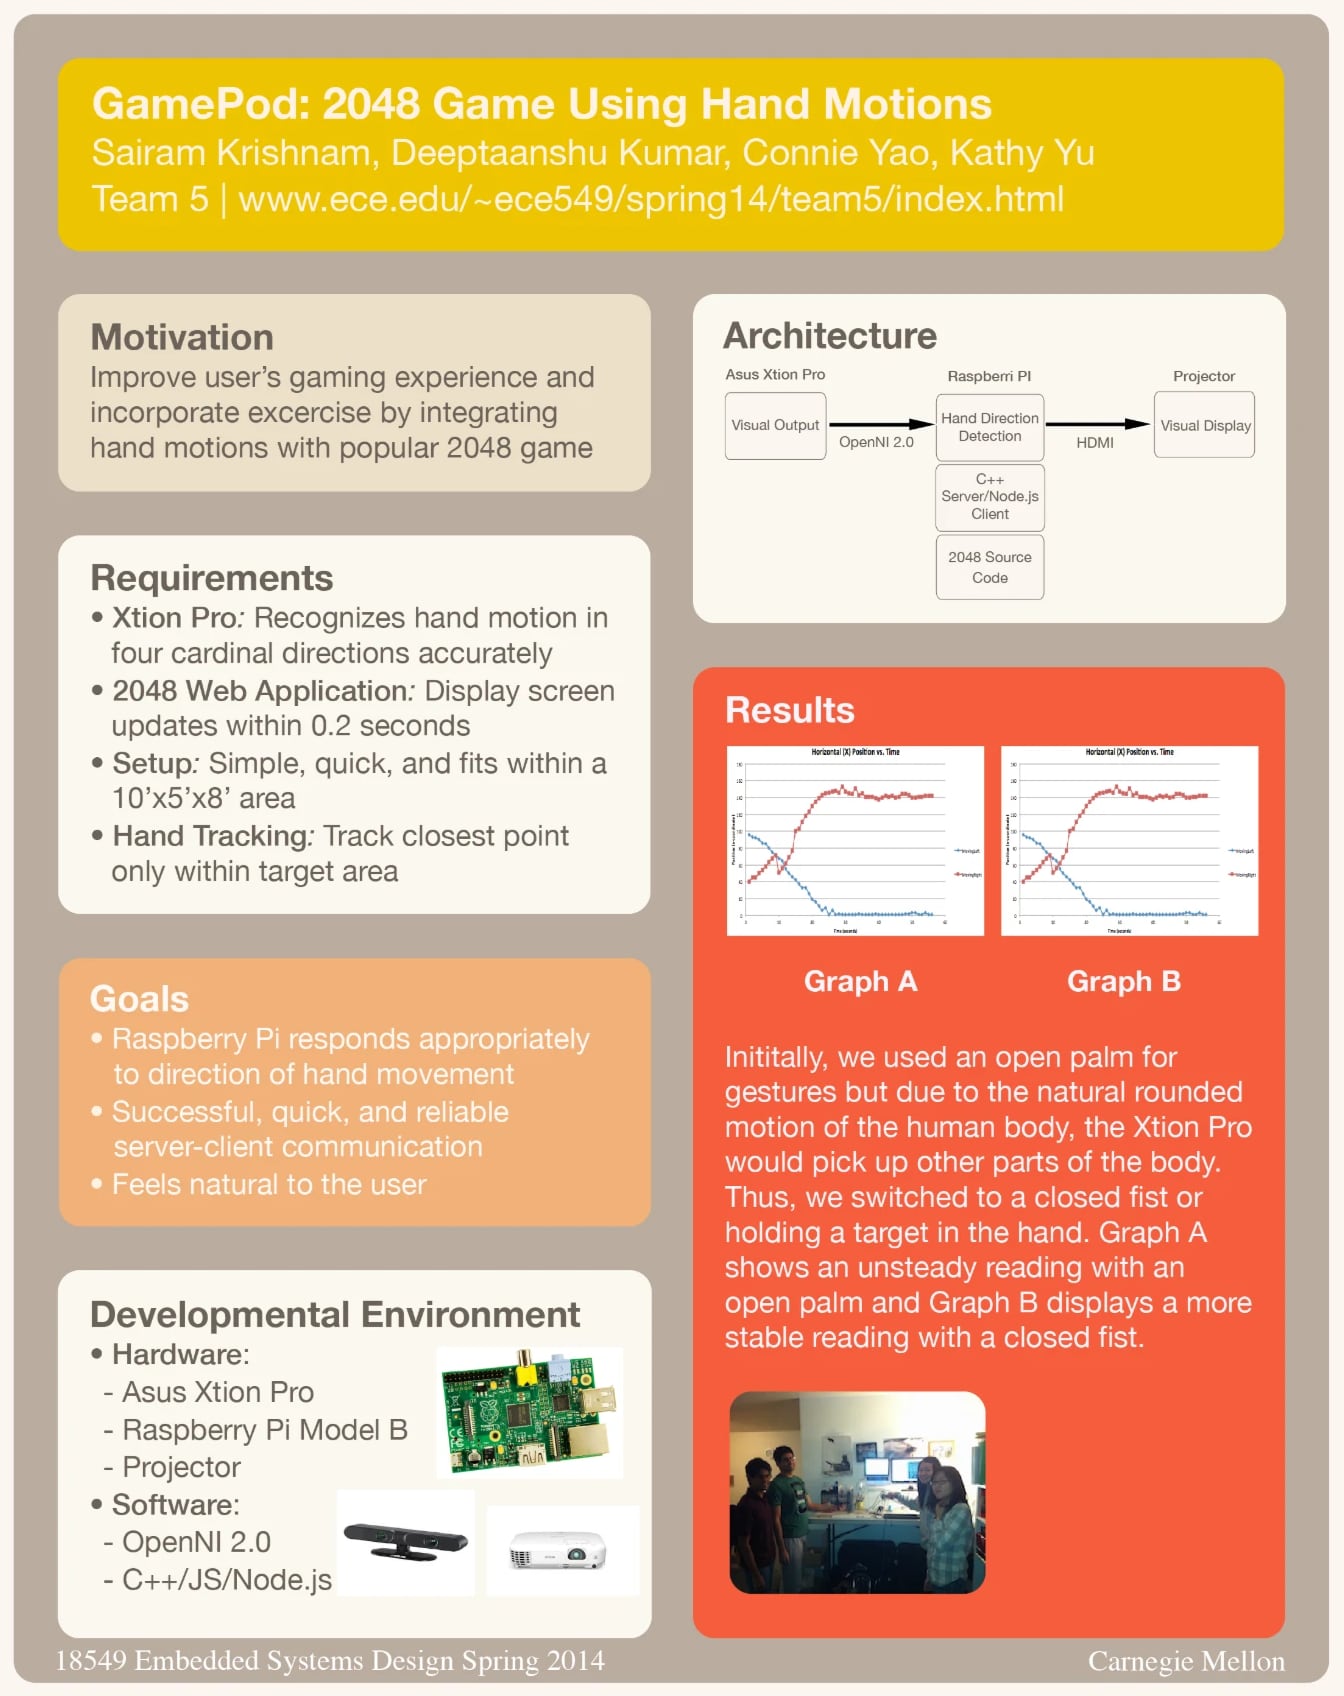
Hand-2048Embedded Capstone (18-549) · Hand-2048Spring 2014Carnegie Mellon University
Reconfigured the hit game 2048 to take hand motions as input, using a Raspberry Pi and an Asus Xtion Pro motion sensor in a motion-sensing-and-actuating framework.
Wrote the team's Raspberry Pi setup guide for headless SSH access from a laptop and for building the OpenNI 2 samples on the Pi.
Switched gesture tracking from an open palm to a closed fist after the Xtion Pro picked up other parts of the body, turning an unsteady position reading into a stable one.
AWSSDE InternMay 2014 - Aug 2014Amazon Web Services (AWS)
Unified the logging system: designed a single common schema for every team's log messages, convinced the teams to adopt it, and consolidated their custom loggers under one shared framework.
Built a log tracer on that framework that traced API calls end to end, pinpointing where in the flow a request failed and what the failure was.
Sped up the logging system 15% for 8M+ customers.
Drone-MegaddonProjects · Drone-MegaddonFall 2014Carnegie Mellon University
Built an end-to-end Android, radio, and embedded-control prototype for commanding drones through a StarCraft-like real-time strategy interface.
Krishnan, S., & Ting, D. (2014). Drone-Megaddon: A Real-Time Strategy Interface for Managing Drone Swarms. engrXiv (archived 2026).
Extended that work in Drone-Megaddon 2026, a proposed architecture connecting language-based intent, visual grounding and tracking, and multi-drone coordination under latency, bandwidth, and human-oversight constraints.